Product Overview
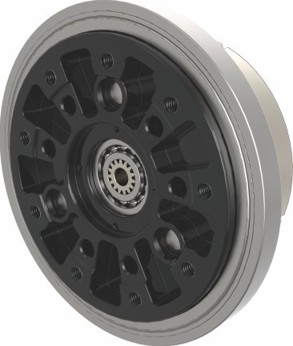
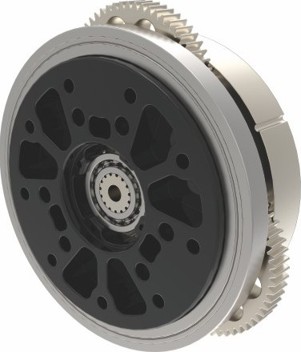
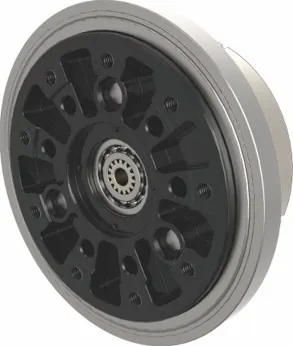
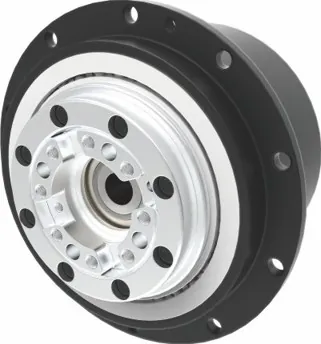
The joint reducer is heavy-duty, long-life rotary drive for the main load-bearing joints of humanoid robots. Built around an integrated outer ring-gear construction, it comes in two frame sizes — AEH072 and AEH088 — with rated outputs of 70 Nm and 100 Nm and a combined peak torque rating up to 200 Nm. This makes the AEH platform the natural choice for shoulders, hips and knees: the joints that carry body weight and absorb the largest impact loads during walking and recovery.
Durability & Build
Durability is where the joint reducer stands apart. Both variants are specified for an average service life of 5000 hours — roughly two-thirds longer than compact high-speed alternatives — while still holding 92% efficiency at full load. The internal gear train uses case-hardened, profile-corrected gearing that meshes smoothly, suppresses operating noise and preserves repeatable accuracy across millions of cycles, even under sustained locomotion and collision loads.
Bearing & Mechanical Design
At the output, a crossed-roller bearing arrangement absorbs combined radial, axial and tilting moments, giving the actuator the stiffness and positional repeatability needed when the robot lands from a step or pushes against its environment. Tight internal clearances keep drag low and the joint responsive, and a central through-hole provides a protected path for motor and sensor cables so wiring stays tidy inside the actuator shell.
Performance
Sealed grease lubrication means minimal scheduled maintenance. Designed for input speeds up to 2400 rpm, the AEH072 (0.67 kg) and AEH088 (0.98 kg) balance torque against mass precisely where the body’s core loads are concentrated, rather than adding unnecessary bulk to the lighter distal joints.
Typical Applications
Typical deployments include bipedal hip and knee actuators, powered shoulder modules, lower-limb exoskeleton drives and heavy collaborative-arm joints. Whether you are scaling up a humanoid for higher payload or designing an exoskeleton for industrial use, the joint reducer line pairs proven our manufacturing with a long-service-life rating, giving integrators a reliable foundation for the body’s hardest-working joints.
Specifications
| Model |
AEH072 |
AEH088 |
| Reduction ratio |
17.457 |
16.312 |
| Rated torque (Nm) |
70 |
100 |
| Peak torque (Nm) |
140 |
200 |
| Rated input speed (rpm) |
1500 |
1500 |
| Max input speed (rpm) |
2400 |
2400 |
| Lubrication |
Grease |
Grease |
| Average service life (h) |
5000 |
5000 |
| Full-load efficiency (%) |
92 |
92 |
| Reference weight (kg) |
0.67 |
0.98 |