Product Overview
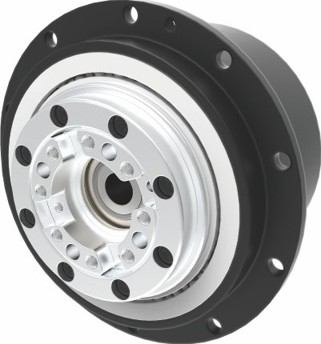
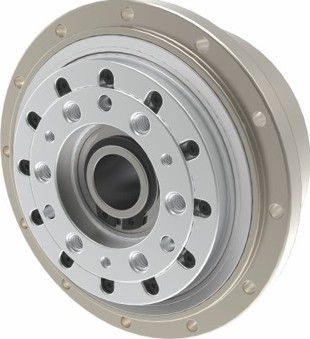
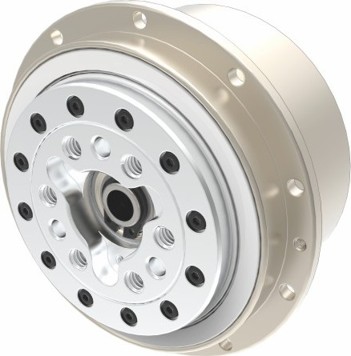
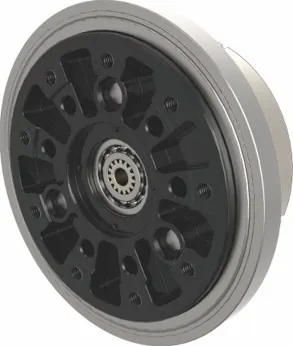
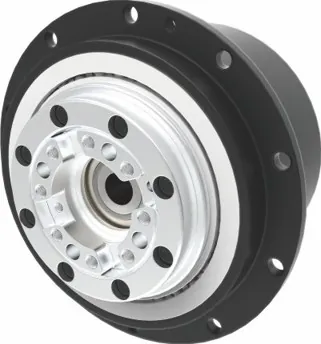
The joint reducer is compact, high-speed precision reducer purpose-built for humanoid robot joints. Available in three frame sizes — ADH045, ADH070 and ADH078 — the platform covers rated torques from 15 Nm up to 50 Nm and peak torques up to 140 Nm, making it easy to match a single motion architecture to lightweight wrists, elbows, ankles and other dynamic joints across the body.
Key Features
It is built around carburized, hardened gears that receive a dedicated tooth-profile modification. The result is low-backlash, low-vibration motion that stays quiet through long operating shifts, while the hardened gear set retains accuracy over repeated duty cycles. A compact housing keeps torque density high, so integrators get usable torque without adding length or mass to the joint stack.
The output end is supported by crossed roller bearings, which combine radial, axial and moment load capacity in a single package. This lets the joint withstand the multi-directional loads typical of walking, stepping and contact-rich tasks without drifting under load. A precision-fitted gear path keeps running resistance low and motion responsive, while the through-bore center hole leaves a clean channel to route cables, sensor leads and drive wiring straight through the joint — a key requirement for clean, serviceable humanoid designs.
Performance
Lubricated for life with grease, the joint reducer runs at 92% full-load efficiency and supports input speeds up to 6000 rpm, with an average service life rated at 3000 hours. Weighing from just 0.3 kg (ADH045), 0.8 kg (ADH070) to 0.9 kg (ADH078), it is engineered for the speed-critical, mass-sensitive joints where every gram and millimetre counts.
Typical Applications
Typical applications include humanoid robot elbow and wrist joints, ankle flexion modules, lightweight dexterous manipulators, collaborative robot arms, and AGV/AMR steering and lift axes where a compact rotary stage is needed. Whether you are developing a research platform, a bipedal prototype or a production humanoid, the ADH line offers a scalable ratio-16 solution built under ISO 9001-controlled production, backed by our precision manufacturing and technical support.
Specifications
| Model |
ADH045 |
ADH070 |
ADH078 |
| Reduction ratio |
16 |
16 |
16 |
| Rated torque (Nm) |
15 |
50 |
30 |
| Peak torque (Nm) |
40 |
100 |
140 |
| Rated input speed (rpm) |
3000 |
3000 |
2300 |
| Max input speed (rpm) |
6000 |
6000 |
3500 |
| Lubrication |
Grease |
Grease |
Grease |
| Average service life (h) |
3000 |
3000 |
3000 |
| Full-load efficiency (%) |
92 |
92 |
92 |
| Reference weight (kg) |
0.3 |
0.8 |
0.9 |